

PathAccLim
Description
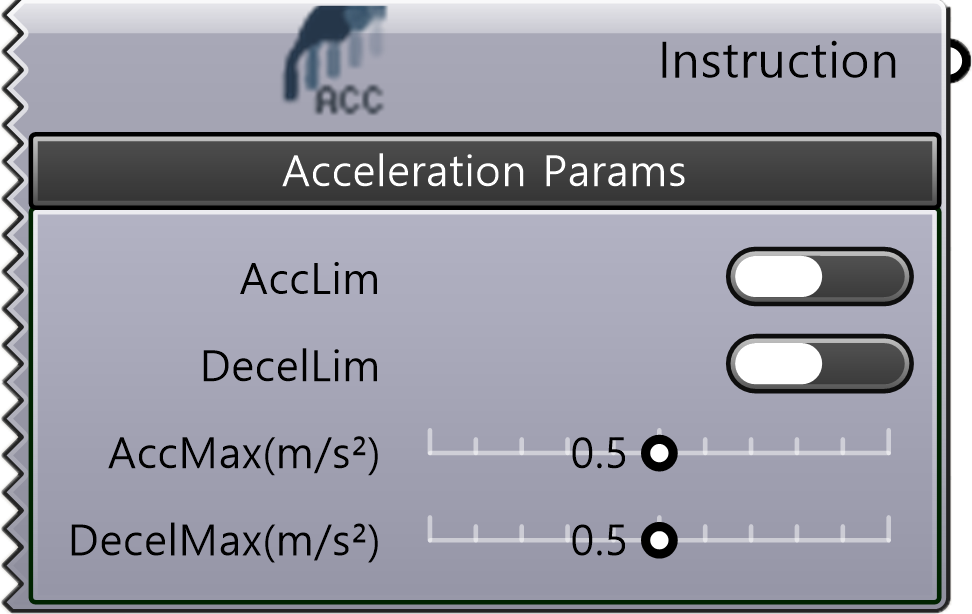
Section titled “Description”PathAccLim is a PathAccLim instruction component that sets or disables the TCP acceleration and deceleration limits along the motion path.
Required Parameter
Section titled “Required Parameter”| Name | Type | Description |
|---|---|---|
| AccLim | Toggle | Set robot acceleration limit (True: Limit, False: No limit) |
| DecelLim | Toggle | Set robot deceleration limit (True: Limit, False: No limit) |
| AccMax(m/s²) | Number | Set maximum robot acceleration (Valid if AccLim is True) |
| DecelMax(m/s²) | Number | Set maximum robot deceleration (Valid if DecelLim is True) |
Output
Section titled “Output”| Name | Type | Description |
|---|---|---|
| Instruction | Instruction | Generated ABB instruction. Pass to the ‘Instructions’ input of the Core component. |