

ToolImporter
Description
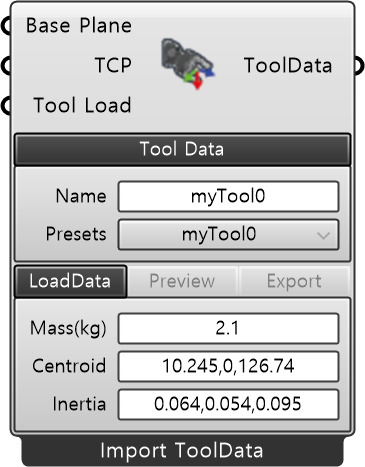
Section titled “Description”Redefines user-defined tool (end-effector) data. The default is tool0, which corresponds to the coordinate system of axis 6 on an ABB robot. You can switch between Define (manual configuration) and Import (loading pre-saved tool data) modes using the right-click context menu.
| Name | Type | Description |
|---|---|---|
| Base Plane | Plane | The tool mounting reference plane relative to the ABB robot flange. Defines the baseline for TCP and geometry (shape). |
| TCP | Plane | The position of the TCP (Tool Center Point) at the end of the tool. Defines its position and orientation relative to the tool base (Base Plane). |
| Tool Load | ToolLoad | The load data (LoadData) of the tool. If not connected, it is estimated and generated based on the bounding box of the tool geometry. |
Required Parameter
Section titled “Required Parameter”| Name | Type | Description |
|---|---|---|
| Tool Name | String | Defines the variable name for the generated ToolData. |
| Preset | Dropdown | List of previously saved ToolData presets. |
| Name | Type | Description |
|---|---|---|
| Mass(kg) | String | Weight (kg) |
| Centroid | String | Center of gravity coordinates (x, y, z) |
| Inertia | String | Moment of inertia (Ix, Iy, Iz) |
| Name | Type | Description |
|---|---|---|
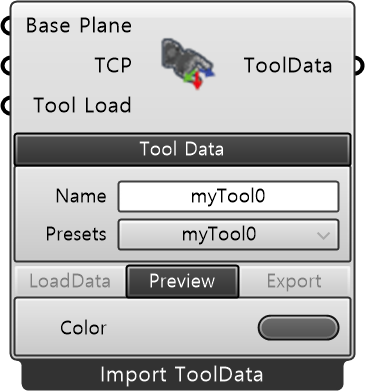
| Color | Color | Visualization color |
| Name | Type | Description |
|---|---|---|
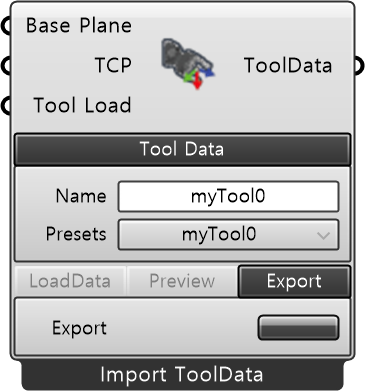
| Export | Button | Saves the tool data as a file to a user-specified local directory. |
Output
Section titled “Output”| Name | Type | Description |
|---|---|---|
| ToolData | ToolData | Outputs the configured ABB ToolData. |