

IndRMove
Description
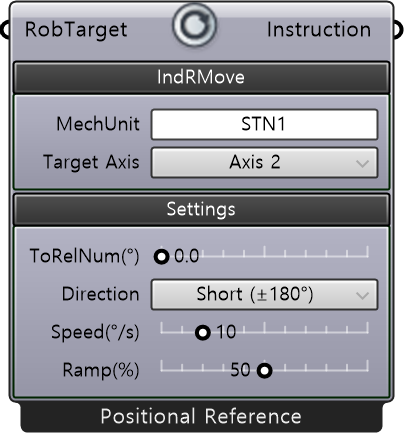
Section titled “Description”This is a component that switches an auxiliary axis to independent mode and moves it to a specified position within one revolution. It is generated using the IndRMove instruction, and after performing the task, it is necessary to initialize it back to normal mode using IndReset.
| Name | Type | Description |
|---|---|---|
| RobTarget | RobTarget | Target position (To Relative Position). Only the corresponding axis component is used. If it is a robot axis, use Target Value (ToRelNum) instead of this parameter. |
Required Parameter
Section titled “Required Parameter”| Name | Type | Description |
|---|---|---|
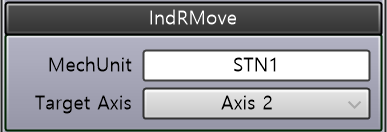
| MechUnit | String | Mechanical unit name. |
| Target Axis | String | Target axis number (1–6). The target axis for returning from independent mode or redefining the logical position. |
| Name | Type | Description |
|---|---|---|
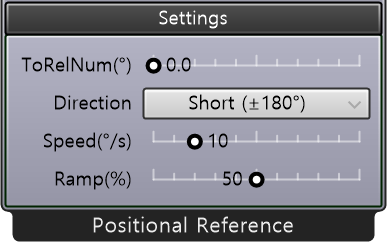
| RefNum(°) | Number | Directly specifies the target position (angle) as a number (°). |
| Direction | String | Movement direction. • Short: Shortest path (within ±180°) • Fwd: Moves in the positive direction (max 360°) • Bwd: Moves in the negative direction (max 360°) |
| Speed | Number | Axis movement speed (°/s). |
| Ramp(%) | Number | Acceleration/deceleration performance reduction ratio (%). 100% = maximum performance. Lower values result in smoother acceleration/deceleration. |
Output
Section titled “Output”| Name | Type | Description |
|---|---|---|
| Instruction | Instruction | Generated ABB instruction. Passed to the Instructions input of the Core component. |