

RobTarget
Description
Section titled “Description”robtarget is a data type that defines the target position, tool orientation, and axis configuration for the robot and auxiliary axes to move to. It defines a RobTarget for robot-only motion without external axes. The external axis values are automatically set to 9E9 (unused).
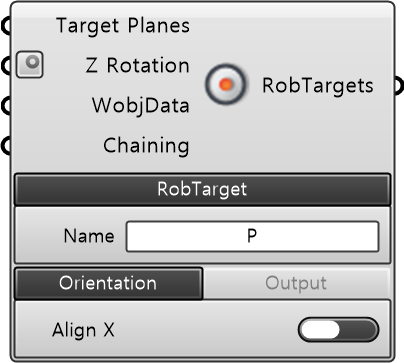
Inputs
Section titled “Inputs”Align Disabled Mode
| Name | Type | Description |
|---|---|---|
| Target Planes | Plane | Input planes to be converted into RobTarget. |
| Z Rotation | Number | Rotates the RobTarget around its own Z-axis (Unit: degrees). |
| WobjData | WobjData | Redefines the Target Plane based on the ABB Work Coordinate System (Optional). |
| Chaining | Boolean | Locks the relationship between the Work Object (WorkObj) and the target (RobTarget). Allows target position and orientation to change when the work object is modified in the viewport (Optional). |
Align Enabled Mode
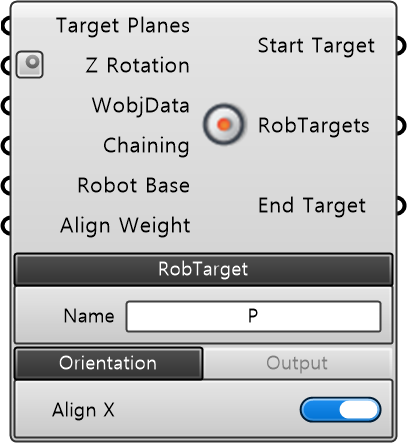
| Name | Type | Description |
|---|---|---|
| Target Planes | Plane | Planes to be converted into RobTarget. |
| Z Rotation | Number | Rotates the RobTarget around its own Z-axis (Unit: degrees). |
| WobjData | WobjData | Redefines the Target Plane based on the ABB Work Coordinate System (Optional). |
| Chaining | Boolean | Locks the relationship between the Work Object (WorkObj) and the target (RobTarget). Allows target position and orientation to change when the work object is modified in the viewport (Optional). |
| Robot Base | Plane | Sets the reference coordinate system that the +X axis of the RobTarget will point toward. The origin of this plane serves as the alignment target point, typically inputting the robot’s base coordinate system (Optional). |
| Align Weight | Number | Interpolation ratio between the original orientation and the fully aligned orientation. 0 = retains original RobTarget orientation, 1 = fully aligns the +X axis toward the Robot Base origin. |
Required Parameter
Section titled “Required Parameter”| Name | Type | Description |
|---|---|---|
| Name | String | Defines the name of the RobTarget variable to be created. This variable is used as a unique identifier storing the target position and orientation of the robot. |
| Name | Type | Description |
|---|---|---|
| Align X | String | An option to interpolate and correct the orientation so that the +X axis of the RobTarget points toward the Robot Base origin. Disabled by default (False). Adds inputs for ‘Robot Base’ (Plane) and ‘Align Weight’ (0 = original, 1 = fully aligned). |
| Name | Type | Description |
|---|---|---|
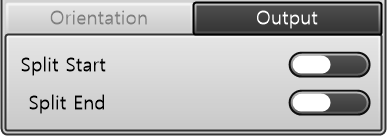
| Split Start | String | Enables separating and outputting data corresponding to the first index within each branch of the input data TargetPlane. |
| Split End | String | Enables separating and outputting data corresponding to the last index within each branch of the input data TargetPlane. |
Outputs
Section titled “Outputs”| Name | Type | Description |
|---|---|---|
| Start Targets | RobTarget | Outputs the first branch data of ABB RAPID RobTargets. |
| RobTargets | RobTarget | Outputs ABB RAPID RobTargets data. |
| End Targets | RobTarget | Outputs the last branch data of ABB RAPID RobTargets. |