

IndReset
Description
Section titled “Description”This is a component that initializes the position and rotation values of an auxiliary axis (IndReset). It is primarily used to initialize accumulated external axis angle values before executing motion instructions.
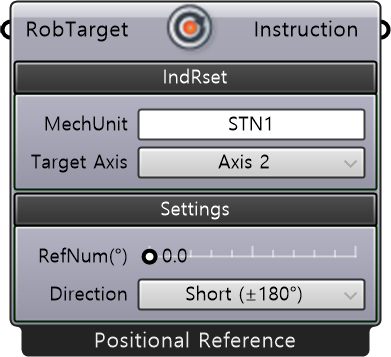
| Name | Type | Description |
|---|---|---|
| RobTarget | RobTarget | Reference position used to realign logical axis angles. Valid only when Direction is Short / Fwd / Bwd. Cannot be used in combination with RefNum. |
Required Parameter
Section titled “Required Parameter”| Name | Type | Description |
|---|---|---|
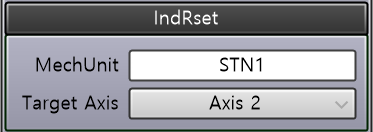
| MechUnit | String | Mechanical unit name. |
| Target Axis | String | Target axis number (1–6). Target for independent mode return or logical position redefinition. |
| Name | Type | Description |
|---|---|---|
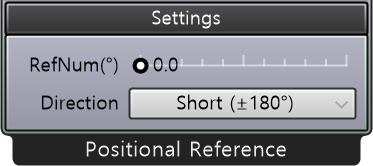
| RefNum(°) | Number | Specifies the measurement reference position as a number (°). Valid only when Direction is Short / Fwd / Bwd. |
| Direction | String | Measurement system adjustment method. • Short: Shortest path to the reference position (within ±180°) • Fwd: Adjusts in the positive direction of the reference position • Bwd: Adjusts in the negative direction of the reference position • Old: Retains the current logical position (default). |
Output
Section titled “Output”| Name | Type | Description |
|---|---|---|
| Instruction | Instruction | Generated ABB instruction. Passed to the Instructions input of the Core component. |