

RealTime Display
Description
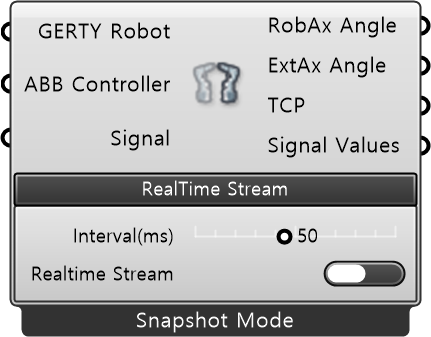
Section titled “Description”A component that streams robot poses and I/O signal states in real time from a connected offline controller and visualizes them through GERTY simulation.
Inputs
Section titled “Inputs”| Name | Type | Description |
|---|---|---|
| GERTY Robot | GERTY Robot | GERTY robot |
| ABB Controller | ABB Controller | ABB Controller connected to the PC |
| Signal | String | Signal name to scan |
Required Parameter
Section titled “Required Parameter”| Name | Type | Description |
|---|---|---|
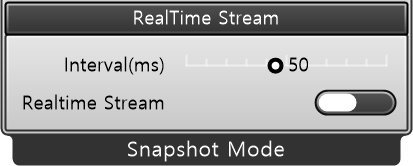
| Interval(ms) | Number | Set real-time stream update interval (milliseconds) |
| RealTime Stream | Toggle | Start/Stop real-time stream |
Output
Section titled “Output”| Name | Type | Description |
|---|---|---|
| RobAx Angle | String | Robot axis angles |
| ExtAx Angle | String | External axis angles |
| TCP | Plane | Current TCP plane |
| Signal Values | Number | Scanned signal values |