

Positioner RobTarget
Description
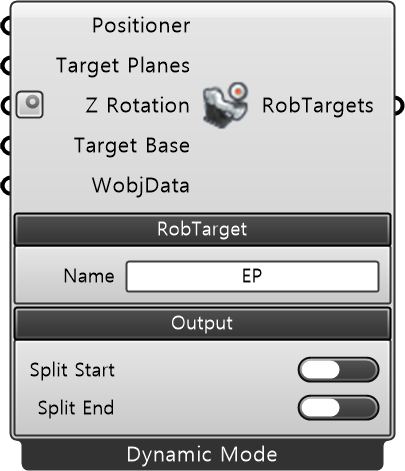
Section titled “Description”Positioner RobTarget defines a RobTarget including the positioner (external axis) rotation angle. You can switch between Dynamic and Static modes by right-clicking the component icon.
Inputs
Section titled “Inputs”Dynamic Mode
| Name | Type | Description |
|---|---|---|
| Positioner | Positioner | ABB Positioner |
| Target Planes | Plane | Planes to be converted into RobTarget |
| Z Rotation | Angle | Rotates the RobTarget based on its own Z-axis (Unit: Degrees) |
| Target Base | Plane | Reference plane where the input Target Plane is defined. The input Target Plane defines the RobTarget oriented to the Positioner’s Mounting Plane based on this plane |
| WobjData | WobjData | Redefines the Target Plane based on the ABB Work Coordinate System. (Optional) |
Top View
Required Parameter
Section titled “Required Parameter”| Name | Type | Description |
|---|---|---|
| Name | String | Defines the name of the RobTarget variable to be created. This variable is used as a unique identifier to store the robot’s target position and orientation. |
| Name | Type | Description |
|---|---|---|
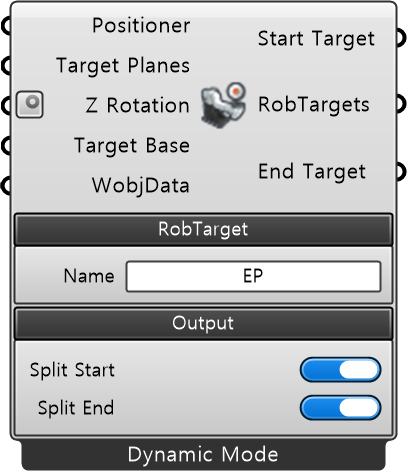
| Split Start | String | Extracts and outputs the data corresponding to the first index in each branch of the input data TargetPlane. |
| Split End | String | Extracts and outputs the data corresponding to the last index in each branch of the input data TargetPlane. |
Outputs
Section titled “Outputs”| Name | Type | Description |
|---|---|---|
| Start Targets | RobTarget | Outputs the first branch data of ABB Rapid RobTargets |
| RobTargets | RobTarget | Outputs ABB Rapid RobTargets data |
| End Targets | RobTarget | Outputs the last branch data of ABB Rapid RobTargets |